Projekt
Improving the Quality of LiDAR Point Cloud Data in Greenhouse Environments
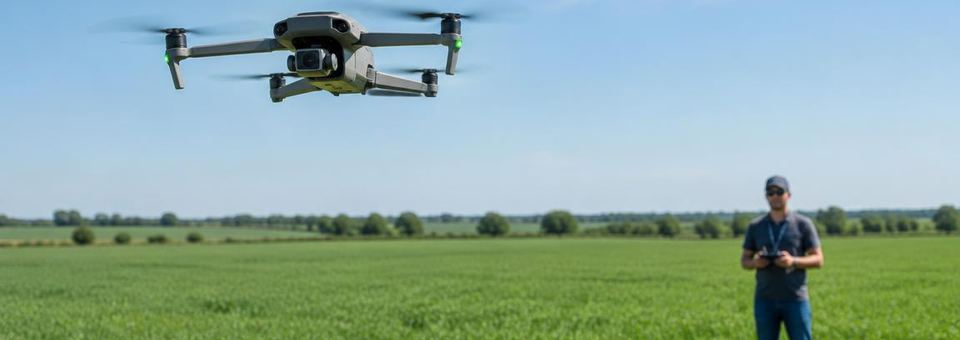
Automated crop monitoring in controlled environments is imperative for enhancing crop productivity. The availability of small unmanned aerial systems (sUAS) and cost-effective LiDAR sensors present an opportunity to conveniently gather high-quality data for crop monitoring. The LiDAR-collected point cloud data, howeve…
Automated crop monitoring in controlled environments is imperative for enhancing crop productivity. The availability of small unmanned aerial systems (sUAS) and cost-effective LiDAR sensors present an opportunity to conveniently gather high-quality data for crop monitoring. The LiDAR-collected point cloud data, however, often encounter challenges such as occlusions and low point density that can be addressed by acquiring additional data from multiple flight paths. This study evaluated the performance of using an Iterative Closest Point (ICP)-based algorithm for registering sUAS-based LiDAR point clouds collected in the greenhouse environment. To address the issue of objects that may cause ICP or local feature-based registration to mismatch correspondences, this study developed a robust registration pipeline. First, the geometric centroid of the ground floor boundary was leveraged to improve the initial alignment, and then piecewise ICP was implemented to achieve fine registration. The evaluation of point cloud registration performance included visualization, root mean square error (RMSE), volume estimation of reference objects, and the distribution of point cloud density. The best RMSE dropped from 20.4 cm to 2.4 cm, and point cloud density improved after registration, and the volume-estimation error for reference objects dropped from 72% (single view) to 6% (post-registration). This study presents a promising approach to point cloud registration that outperforms conventional ICP in greenhouse layouts while eliminating the need for artificial reference objects.
Hochschulen
- THE OHIO STATE UNIVERSITY THE OHIO STATE UNIVERSITY – Hochschule bzw. Forschungseinrichtung mit Aktivitäten in Forschung und Innovation.